Terrano Tracked Robot
A connected tracked robot - controlled from a phone over Bluetooth, firmware updated remotely over the web (OTA), with live telemetry.
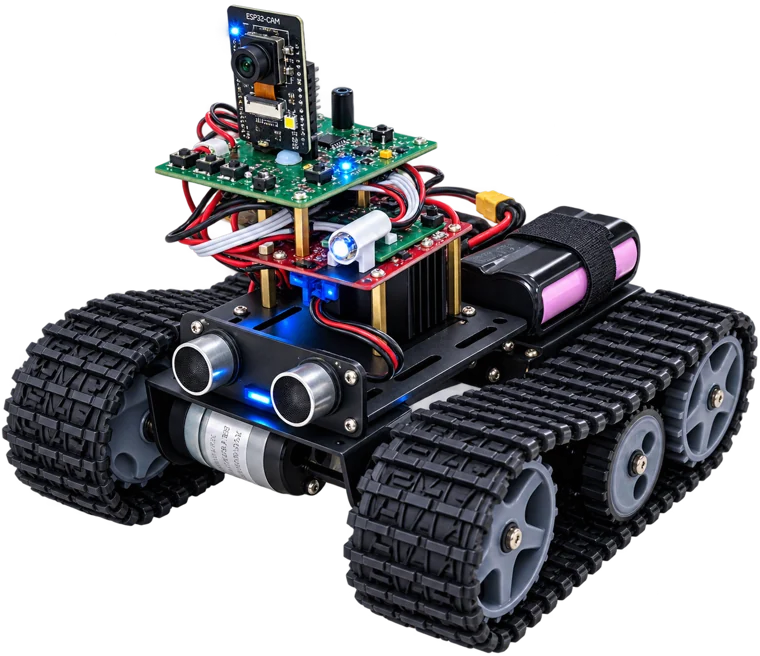
A video with phone control and OTA updates is coming soon.
The robot is built on an ESP32. It is driven from a mobile app (Flutter) over Bluetooth Low Energy or straight from the web over MQTT with about 50 ms of latency, its firmware is updated remotely over the web (OTA), and its status and telemetry stream live into a web dashboard.
Phone control
Drive it over Bluetooth from the app
Drive from the web
MQTT, ~50 ms, stops itself if the link drops
OTA updates
New firmware remotely over the web
Live telemetry
Status and data in real time
Custom firmware
Written from scratch in C/C++
Preview mode - controls are active only with a password.
A little note: the project started at home from a Lego Friends robot named “Zobo” that the kids wanted to put a hamster inside. 🐹 A toy turned into a development platform.